
Top AI Repos — open-source AI, indexed and scored
Top AI Repos tracks AI repositories on GitHub and answers two different questions about each one: is it moving right now, and would you bet a product on it.
Top AI Repos tracks AI repositories on GitHub and answers two different questions about each one: is it moving right now, and would you bet a product on it.

Intrinsic3D - High-Quality 3D Reconstruction by Joint Appearance and Geometry Optimization with Spatially-Varying Lighting (ICCV 2017)
| Date | Stars |
|---|---|
| 2026-07-30 | 458 |
| 2026-08-18 | 458 |
| 2026-08-19 | 458 |
| 2026-09-15 | 459 |
| 2026-10-12 | 458 |
| 2026-10-18 | 459 |
| 2026-10-23 | 460 |
| 2026-11-04 | 460 |
Today
— stars today
This week
— stars this week
This month
+1 stars this month
Momentum
0.0
growth rate 0.00%/day
# Intrinsic3D
## High-Quality 3D Reconstruction by Joint Appearance and Geometry Optimization with Spatially-Varying Lighting (ICCV 2017)
[](https://vision.in.tum.de/_media/spezial/bib/maier2017intrinsic3d.pdf)
### License ###
Copyright (c) 2019, NVIDIA Corporation and Technical University of Munich. All Rights Reserved.
The Intrinsic3D source code is available under the [BSD license](http://opensource.org/licenses/BSD-3-Clause), please see the [LICENSE](LICENSE) file for details.
All data in the [Intrinsic3D Dataset](https://vision.in.tum.de/data/datasets/intrinsic3d) is licensed under a [Creative Commons 4.0 Attribution License (CC BY 4.0)](https://creativecommons.org/licenses/by/4.0/), unless stated otherwise.
### Resources ###
* [Project page @ NVIDIA Research](https://research.nvidia.com/publication/2017-10_Intrinsic3D%3A-High-Quality-3D)
* [Intrinsic3D Dataset @ TUM](https://vision.in.tum.de/data/datasets/intrinsic3d)
* [ICCV 2017 Paper (PDF)](https://vision.in.tum.de/_media/spezial/bib/maier2017intrinsic3d.pdf)
* [ArXiv (PDF)](https://arxiv.org/pdf/1708.01670.pdf)
### Project members ###
* [Robert Maier](https://vision.in.tum.de/members/maierr), Technische Universität München
* [Kihwan Kim](https://research.nvidia.com/person/kihwan-kim), NVIDIA
* [Daniel Cremers](https://vision.in.tum.de/members/cremers), Technische Universität München
* [Jan Kautz](https://research.nvidia.com/person/jan-kautz), NVIDIA
* [Matthias Nießner](http://www.niessnerlab.org/members/matthias_niessner/profile.html), Technische Universität München
## Summary
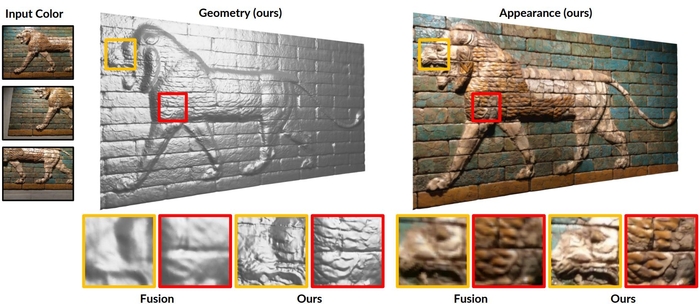
**Intrinsic3D** is a method to obtain high-quality 3D reconstructions from low-cost RGB-D sensors.
The algorithm recovers fine-scale geometric details and sharp surface textures by simultaneously optimizing for reconstructed geometry, surface albedos, camera poses and scene lighting.
This work is based on our publication
* [Intrinsic3D: High-Quality 3D Reconstruction by Joint Appearance and Geometry Optimization with Spatially-Varying Lighting](https://vision.in.tum.de/_media/spezial/bib/maier2017intrinsic3d.pdf)
International Conference on Computer Vision (ICCV) 2017.
If you find our source code or [dataset](https://vision.in.tum.de/data/datasets/intrinsic3d) useful in your research, please cite our work as follows:
```
@inproceedings{maier2017intrinsic3d,
title = {{Intrinsic3D}: High-Quality {3D} Reconstruction by Joint Appearance and Geometry Optimization with Spatially-Varying Lighting},
author = {Maier, Robert and Kim, Kihwan and Cremers, Daniel and Kautz, Jan and Nie{\ss}ner, Matthias},
booktitle = {International Conference on Computer Vision (ICCV)},
year = {2017}
}
```
## Installation
As the code was mostly developed and tested on Ubuntu Linux (16.10 and 18.10), we only provide the build instructions for Ubuntu in the following.
However, the code should also work on Windows with Visual Studio 2013.
Please first clone the source code:
```
git clone https://github.com/NVlabs/intrinsic3d.git
```
### Dependencies
Building Intrinsic3D requires
[CMake](https://cmake.org/download/),
[Eigen](http://eigen.tuxfamily.org/),
[OpenCV 4](https://opencv.org/releases.html),
[Boost](http://www.boost.org/users/download/) and
[Ceres Solver](http://ceres-solver.org/) (with [CXSparse](https://github.com/TheFrenchLeaf/CXSparse) on Windows)
as third-party libraries.
The following command installs the dependencies from the default Ubuntu repositories:
```
sudo apt install cmake libeigen3-dev libboost-dev libboost-filesystem-dev libboost-graph-dev libboost-system-dev libopencv-dev
```
Please install [Ceres Solver](http://ceres-solver.org/installation.html) using the following commands (if not installed already):
```
# create third_party subdirectory (in Intrinsic3D root folder)
mkdir third_party && cd third_party
# install Ceres Solver dependencies
sudo apt inExcerpt of 9,629 characters
Read on GitHubWould you bet a product on this? Bounded 0–100 and slow moving.
matched fp:3523dc748f53b253, topic:computer-vision, topic:3d-reconstruction, readme:computer vision